人形机器人来源已核对
DOBOT ATOM
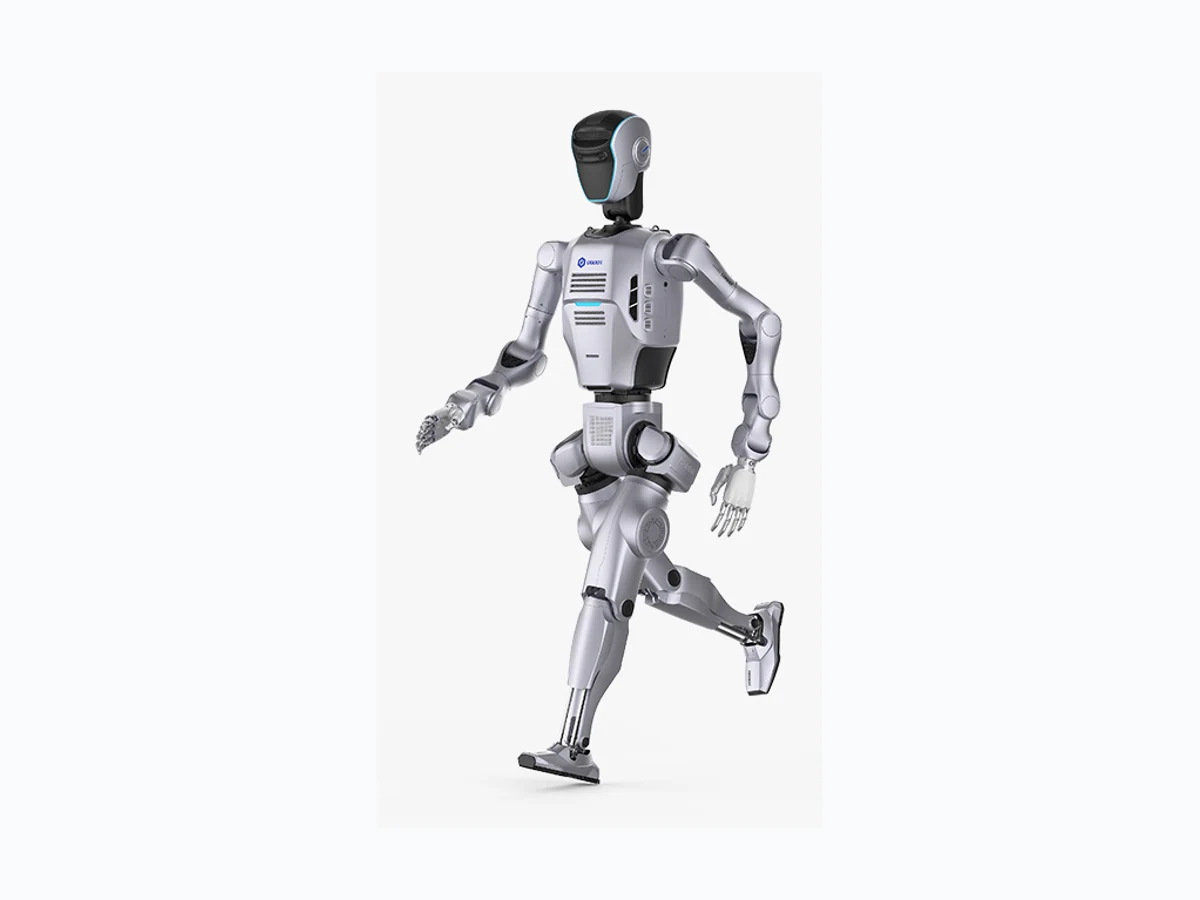
DOBOT · ATOM Max — research configuration
面向研究的 ATOM Max 配置,官方页面明确 41 自由度及视觉、遥操作能力;交付套件和未公开机械参数需由厂商确认。
自由度 / 轴数41 DOF
供货情况需询问
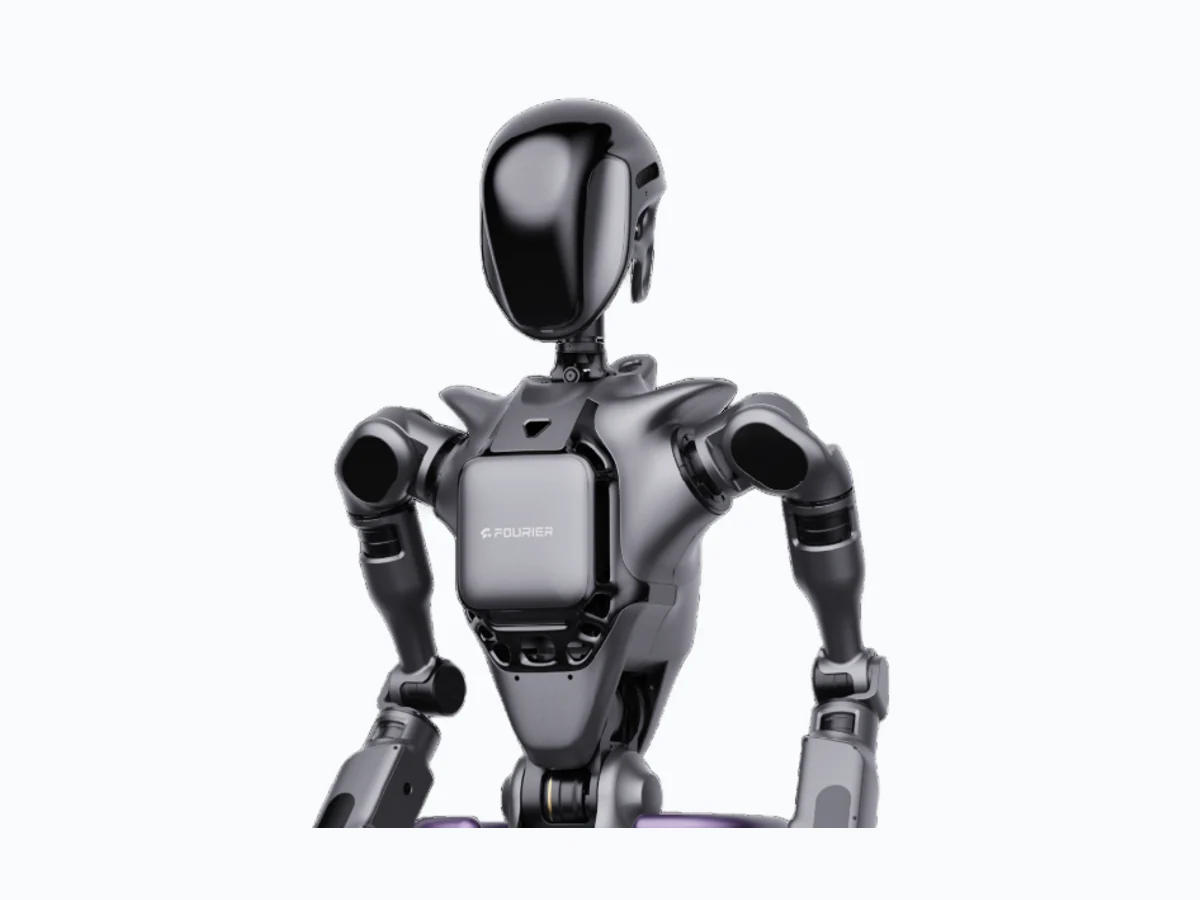
具备灵巧手的人形科研平台,官方彩页 GR-1 列记录约 55 kg、44 个执行器;不同代际和末端配置需确认。
| 参数 | 公开数值与条件 |
|---|---|
| 高度 | 1650 mm GR-1 — dexterous-hand configuration 来源 · 2026年10月24日 |
| 设备重量 | 55 kg GR-1 — dexterous-hand configuration 来源 · 2026年10月24日 |
| 外形尺寸 | 1650 × 515 × 320 mm GR-1 — dexterous-hand configuration 来源 · 2026年10月24日 |
| 执行器数量 | 44 actuators GR-1 — dexterous-hand configuration 来源 · 2026年10月24日 |
| 手臂负载 | 3 kg GR-1 — dexterous-hand configuration 来源 · 2026年10月24日 |
| 最大关节扭矩 | 230 N·m GR-1 — dexterous-hand configuration 来源 · 2026年10月24日 |
| 公开最高速度 | 5 km/h GR-1 — dexterous-hand configuration 来源 · 2026年10月24日 |
Uses GR-1 column, not GR-1L or Pro. Older developer documentation lists another weight; the dated brochure is the recorded baseline. / 采用 GR-1 列,不混用 GR-1L 或 Pro;旧开发文档重量不同,以本规格页为记录基线。
资料核对仅表示将公开信息与记录来源比对,不代表工厂审核、认证审查或独立产品测试。
official document · 资料核对 2026年10月24日
official product · 资料核对 2026年10月20日
继续研究
DOBOT · ATOM Max — research configuration
面向研究的 ATOM Max 配置,官方页面明确 41 自由度及视觉、遥操作能力;交付套件和未公开机械参数需由厂商确认。
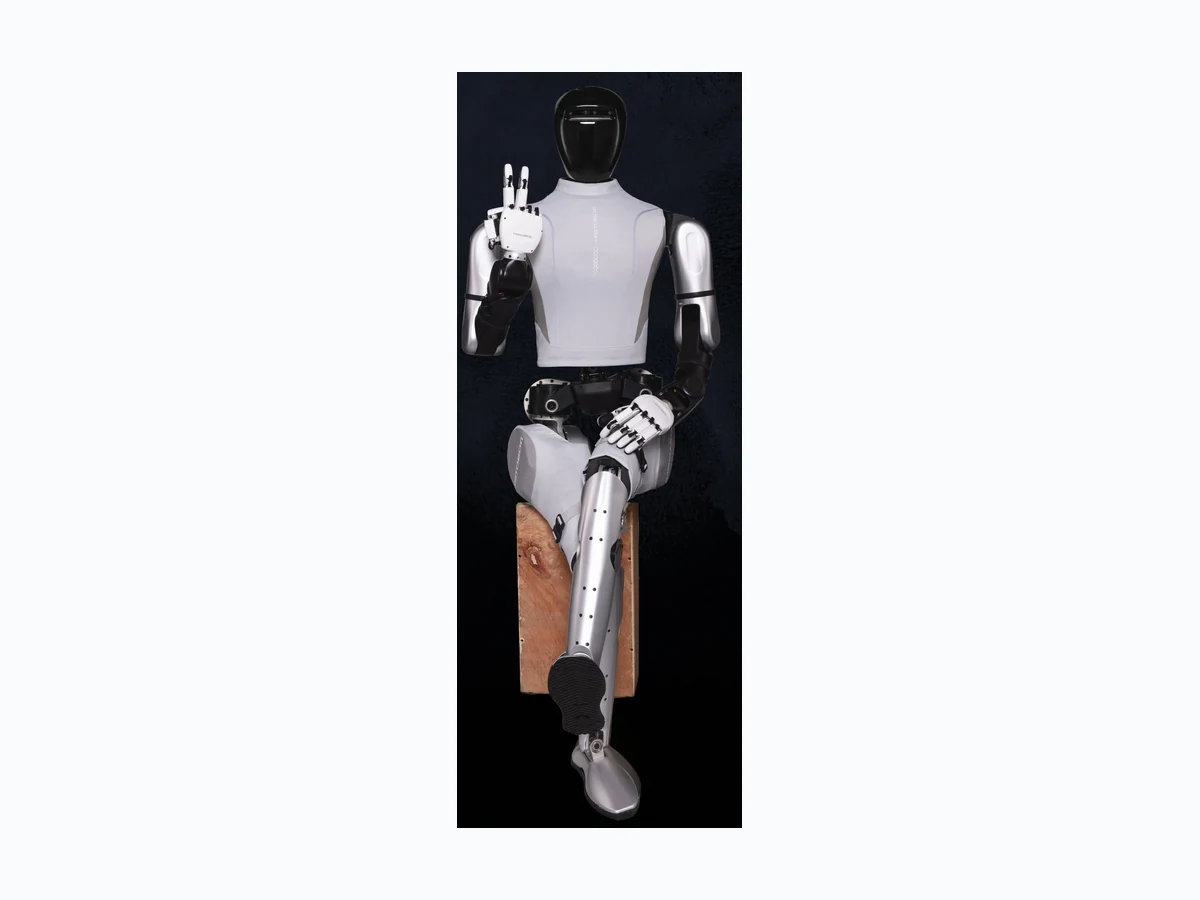
RobotEra · STAR1 — official brochure
STAR1 人形研究平台,官方彩页记录高 1710 mm、重 63 kg、55 自由度,传感器与算力配置应随交付确认。
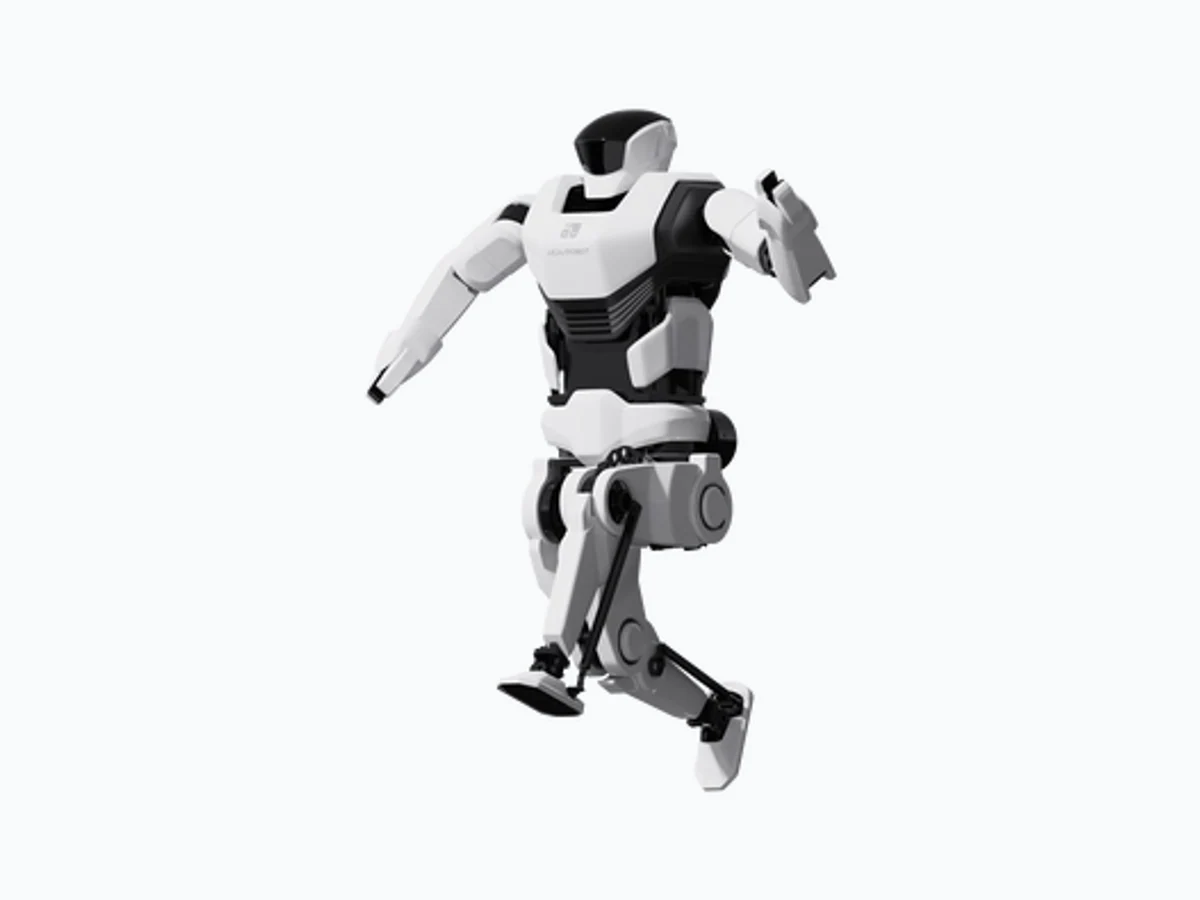
Leju Robot · KUAVO 4.1 — documented configuration
按乐聚 KUAVO 4.1 官方手册展示的研究平台,身高 1550 mm、重量 50 kg、行走续航 1.5 小时,不套用其他代际数据。